Yulun Tian’s Academic Website
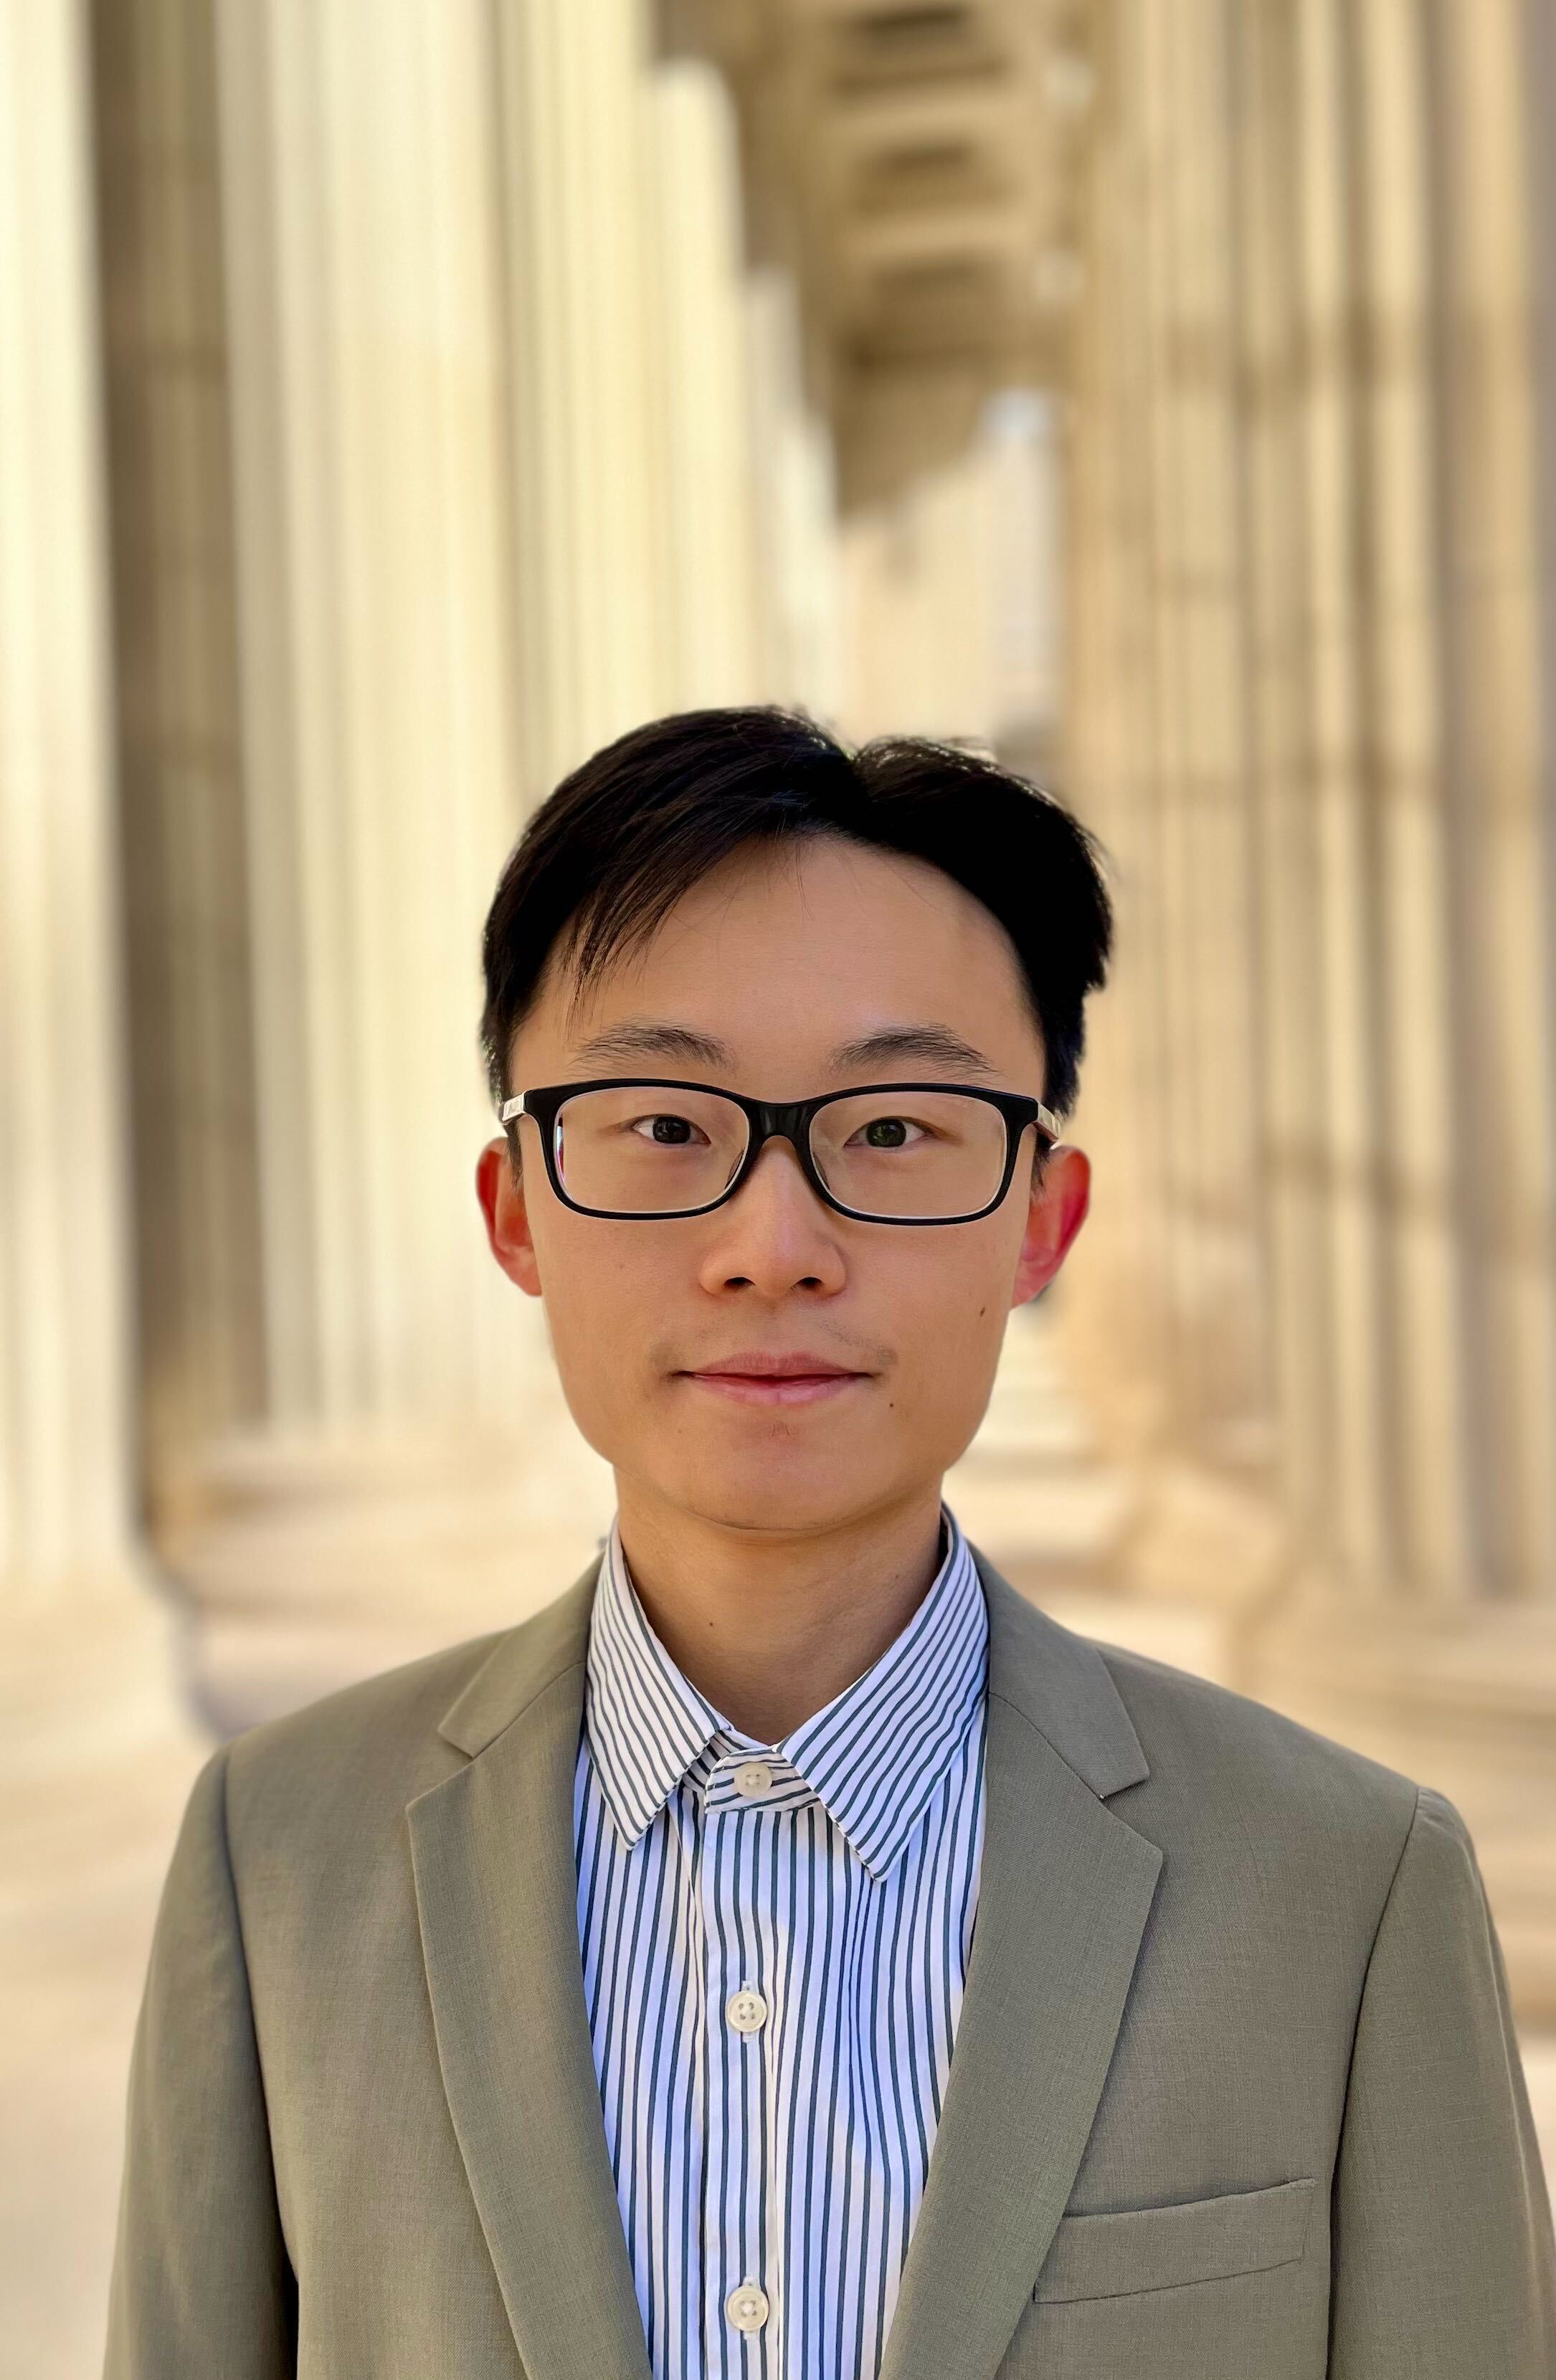
I am an Assistant Professor in the Robotics Department at the University of Michigan, where I direct the Scalable Spatial Intelligence Lab. I am passionate about developing scalable and trustworthy autonomy that operates robustly over long periods of time without human intervention. My research applies tools from nonlinear and distributed optimization, machine learning, and graph theory to develop principled algorithms with theoretical guarantees and real-world systems for spatial perception, navigation, and multi-agent systems.
Before joining Michigan Robotics, I was a Postdoctoral Scholar at the UC San Diego Contextual Robotics Institute (CRI) and the MIT Laboratory for Information and Decision Systems (LIDS). I received my PhD degree from MIT AeroAstro in August 2023, with a focus on autonomous systems. During my PhD, I was very fortunate to be advised by Prof. Jonathan How. Prior to PhD, I received my SM degree (2019) from MIT and BA degree (2017) from UC Berkeley.
Prospective Students: if you would like to get involved with my group’s research, please check this link for currently open opportunities!
Selected News
- [Sep. 2026] The SSI lab received the 2026 Samsung START grant.
- [Sep. 2026] DeepCORD and SERF are accepted to CoRL 2026.
- [Jul. 2026] LatentAM is accepted to IEEE RA-L.
- [Jun. 2026] Serving as an Area Chair for CoRL 2026.
- [Mar. 2026] Serving as an Associate Editor for IROS 2026.
- [Aug. 2025] The Scalable Spatial Intelligence Lab officially launched at Michigan Robotics. Check out our website!
- [Dec. 2024] My PhD thesis received the 2024 best dissertation award from the IEEE RAS TC for Multi-Robot Systems. A big thank you to the MRS TC for promoting research and building community in this field!
- [Jun. 2024] Serving as an Associate Editor for the International Journal of Robotics Research (IJRR).
Selected Awards and Honors
- Best Dissertation Award, IEEE RAS TC for Multi-Robot Systems, 2024.
- Outstanding Reviewer, IEEE Robotics and Automation Letters (RA-L), 2023.
- Best Paper Award, IEEE Transactions on Robotics (T-RO), 2022.
- Honorable Mention for Best Paper, IEEE Transactions on Robotics (T-RO), 2021.
- Honorable Mention for Best Paper, IEEE Robotics and Automation Letters (RA-L), 2020.